Masazumi Imai
Ph.D. Student · Space Robotics Lab, Tohoku University
Welcome to my world!
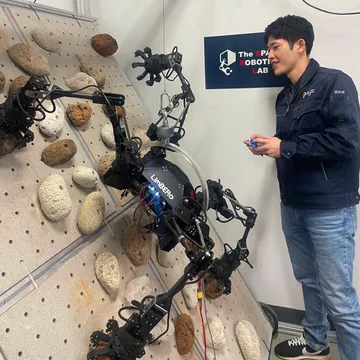
My research focuses on space robotics, specifically multi-limbed articulated systems for lunar/planetary exploration and on-orbit missions. Key areas include motion planning and control for limbed climbing robots that traverse rough terrain and assist astronauts on space stations.
What's New
- Our paper was accepted at iSpaRo 2026.
- Our paper was accepted at IEEE ICRA 2026.
- This website was launched.
Research Highlights
View all >>
Lunar and Planetary Climbing Exploration: Limbed Climbing Robotics
Developing a four-limbed climbing robot capable of traversing diverse terrain to explore rough surfaces and rocky cliffs on the Moon and planets.

Intra-Vehicular Mobility in Space Stations
Developing locomotion planning and control for multi-limbed robots, toward automating crew tasks inside space stations.

Locomotion in Microgravity
Studying reaction-aware motion planning and control for limbed robots moving in microgravity environments, such as asteroids.
Selected Publications
View all >>Graph-Based Simultaneous Path and Foothold Planning for Multi-Limbed Intra-Vehicular Robots in Space Stations
Proceedings of the International Conference on Space Robotics (iSpaRo), pp. TBD, 2026
LIMBERO: A Limbed Climbing Exploration Robot Towards Traveling on Rocky Cliffs
Proceedings of the IEEE International Conference on Robotics and Automation (ICRA), 2026
* These authors contributed equally to this work.
Admittance Control-based Floating Base Reaction Mitigation for Limbed Climbing Robots
Proceedings of the 27th International Conference Series on Climbing and Walking Robots and the Support Technologies for Mobile Machines (CLAWAR 2024), vol. 1115, pp. 157-168, 2024
RAMP: Reaction-Aware Motion Planning of Multi-Legged Robots for Locomotion in Microgravity
Proceedings of the IEEE International Conference on Robotics and Automation (ICRA), pp. 11845-11851, 2023