今井 正純
博士後期課程 · 東北大学 工学研究科 航空宇宙工学専攻 宇宙ロボット研究室
Welcome to my world!
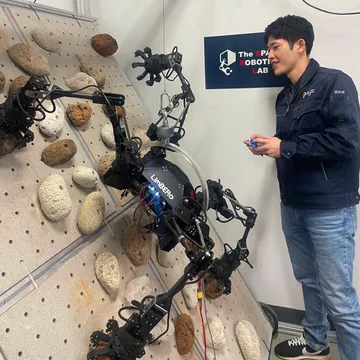
宇宙ロボティクス,特に月惑星探査や軌道上ミッションに向けた多肢型ロボットの研究に取り組んでいます.不整地を移動する脚型クライミングロボットや,宇宙ステーション内で宇宙飛行士を支援するロボットを対象に,動作計画および制御の研究をしています.
ニュース
- 筆頭著者の論文が iSpaRo 2026 に採択されました.
- 脚型クライミングロボット LIMBERO に関する論文が IEEE ICRA 2026 に採択されました.
- 本ウェブサイトを開設しました.
研究紹介
すべて見る >>


主な研究業績
すべて見る >>Graph-Based Simultaneous Path and Foothold Planning for Multi-Limbed Intra-Vehicular Robots in Space Stations
Proceedings of the International Conference on Space Robotics (iSpaRo), pp. TBD, 2026
LIMBERO: A Limbed Climbing Exploration Robot Towards Traveling on Rocky Cliffs
Proceedings of the IEEE International Conference on Robotics and Automation (ICRA), 2026
* These authors contributed equally to this work.
Admittance Control-based Floating Base Reaction Mitigation for Limbed Climbing Robots
Proceedings of the 27th International Conference Series on Climbing and Walking Robots and the Support Technologies for Mobile Machines (CLAWAR 2024), vol. 1115, pp. 157-168, 2024
RAMP: Reaction-Aware Motion Planning of Multi-Legged Robots for Locomotion in Microgravity
Proceedings of the IEEE International Conference on Robotics and Automation (ICRA), pp. 11845-11851, 2023